Bionic Shoe Design & Optimization Proposal
A systematic foot-end solution for full-size bipedal humanoid robots, addressing shock absorption, quietness, anti-slip, wear resistance, all-terrain mobility, standardization and maintainability.
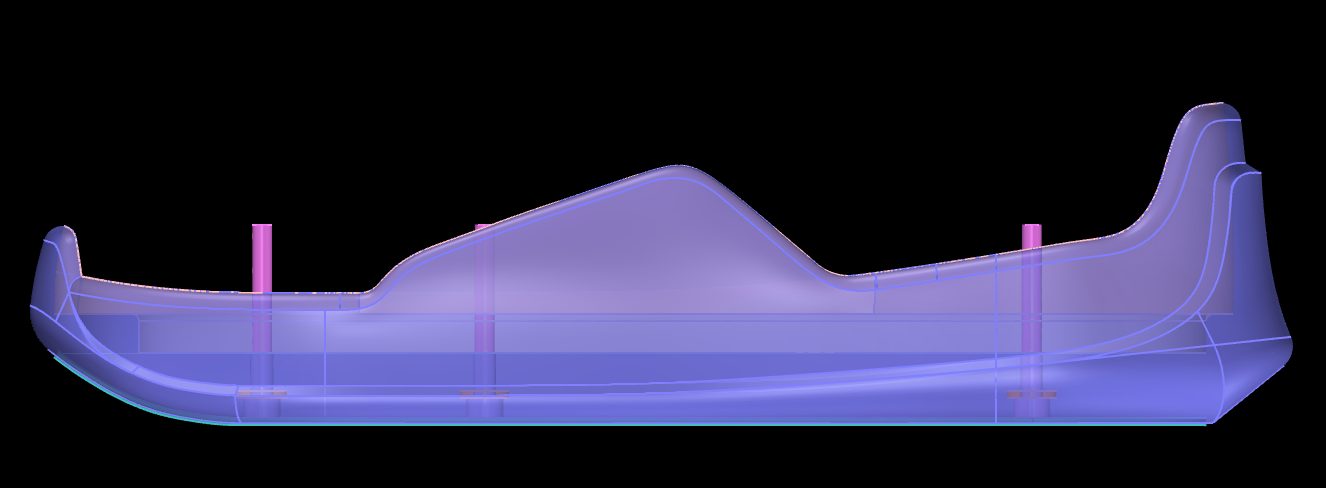
Solid flat support structure — hollow gaps eliminated
Six Weaknesses of the Traditional “Aluminum Plate + Rubber Pad” Solution
The traditional solution — an aluminum foot plate bonded with a single-density rubber pad (about 5–15 mm thick) — works in a flat lab environment, but exposes six systematic weaknesses in real industrial and outdoor conditions:
Weak Shock Absorption & Noise
Single-density rubber cannot cushion the impact of a 60+ kg robot in motion. Ground reaction forces pass straight into joints and waist drivetrain during intense or long runs, accelerating wear and dominating walking noise.
Poor Terrain Mobility
A flat aluminum plate has no toe/heel spring (approach/departure angle). Mobility collapses on slopes, stairs, obstacles and uneven, oily, muddy or sandy ground.
Loosening & Detachment
Aluminum and rubber are locked only by screws with small hard-side nuts — a weak bond to soft rubber that fails pull-out tests; intense motion or long walks lead to loosening, delamination, detachment and accelerated wear.
Consumable, Hard to Maintain
The foot sole is a consumable replaced every 1,000–2,000 hours. Glued designs ignore this replacement need, piling pain onto customer experience and field maintenance.
No Cover, No Protection
A bare flat plate fails both human aesthetics and the mainstream bionic look; without an upper it collects water and dust, takes knocks, and offers no shelter for future in-shoe electronics.
Too Many SKUs, High Cost
Humanoid models are numerous and iterate fast. Making plate and pad separately then integrating them multiplies molds, SKUs, spare-part types and inventory, inflating production, after-sales and supply-chain overhead.
| Pain Point | Direct Consequence | Affected Systems |
|---|---|---|
| Weak shock absorption & noise | Accelerated joint wear, loud walking noise | Knee joints / waist drivetrain / noise compliance |
| Poor terrain mobility | Snagging on slopes and stairs, slipping on wet ground | Motion control / mission completion rate |
| Loosening & detachment | Sole delamination, loss, unplanned downtime | Whole-machine safety / O&M cost |
| Consumable, hard to maintain | Replacement every 1,000–2,000 h, frequent downtime | Spares / after-sales / availability |
| No cover, no protection | Water & dust ingress, exposed devices | Reliability / confidentiality / aesthetics |
| Too many SKUs, high cost | Many molds, complex SKUs | Supply chain / mass-production economics |
The RobotSole Standardized · Modular Solution
For the mainstream direction ahead, we propose an integrated, maintainable architecture of “standard foot plate + dual-density composite sole + standardized interface” — upgrading the foot end from fragile separate parts to mass-producible standard components without sacrificing performance.
Standard Foot Plate + Dual-Density Composite Sole
Optimized as a solid flat support structure that eliminates hollow gaps under the sole; plate structural strength, effective ground-contact area gain and bonding compatibility with the cushioning layer are verified in sync, delivering finalized 3D drawings for official mold development.
Solid flat support structure — hollow gaps eliminated
Standardized Bolt Holes & Interface
Unified Specification
Unify foot-end mounting hole positions, locating dimensions and interface specs into a modular standard-part system compatible with multiple generations and models of humanoid robots.
Universal Interchange
Verified interface universality and interchangeability reduce model-specific molds and SKU complexity, simplify assembly, warehousing and after-sales, and lay the standardization groundwork for mass production and full-range adaptation.
Recommended Design Improvements
Dual-Density Composite Sole
A ~70 A bottom rubber — anti-slip, wear-resistant, gripping on oil-wet ground and aging-resistant — is bonded with ~40 A elastic cushioning rubber to balance wear life and energy absorption; a built-in large-diameter metal washer lets the lock nut clamp on metal instead of soft rubber, greatly improving pull-out strength and fastening reliability.
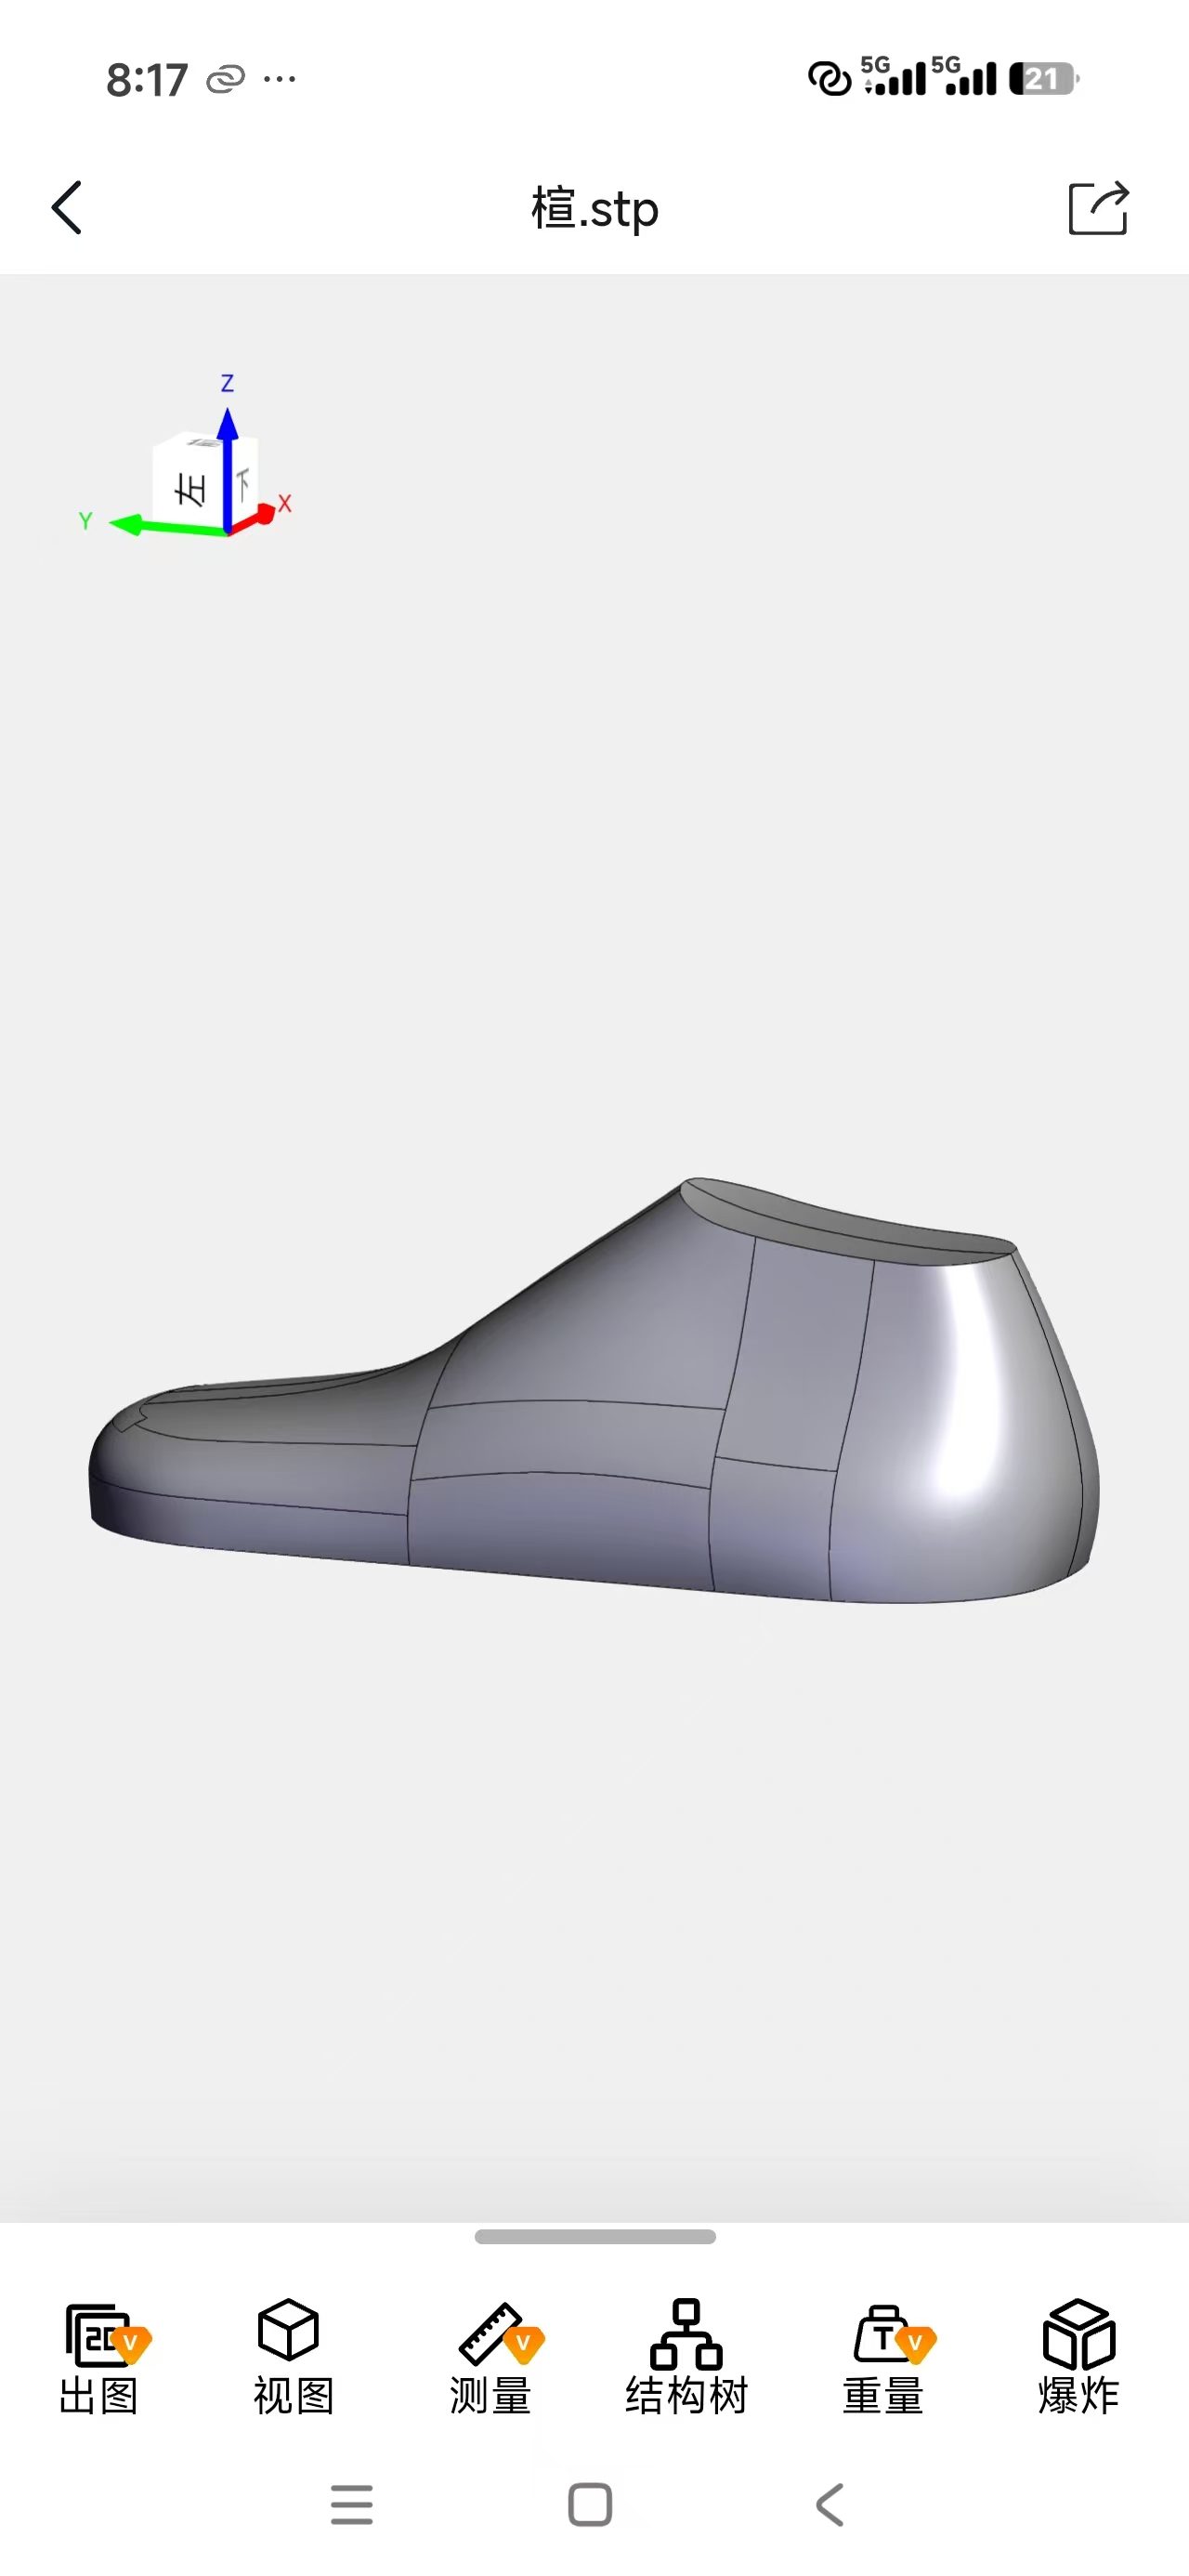
Dual-density composite sole with built-in metal washer
Bionic Outer Profile
Following the natural human foot — narrower forefoot, rounded heel, inward-curved arch — the streamlined silhouette replaces rigid geometric outlines, matching the humanoid bionic design language and improving overall visual harmony, with zero extra material or tooling cost.
Toe & Heel Spring Angles
10°–15° front toe spring (approach angle) and 8°–12° heel spring (departure angle) mimic human toe-off and heel-strike, improving slope walking and ditch-crossing mobility without changing effective ground-contact area, walking balance or control data.
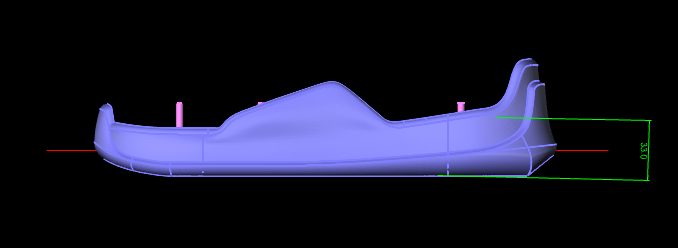
Toe/heel springs for all-terrain mobility
Zoned Anti-Slip Tread
The contact-layer rubber carries a human-foot-inspired zoned texture — transverse grip grooves on the forefoot, cushioning pattern on the heel, reinforcing ribs in the arch — optimizing traction and load distribution without extra process complexity, following bionic mechanics with a refined look.
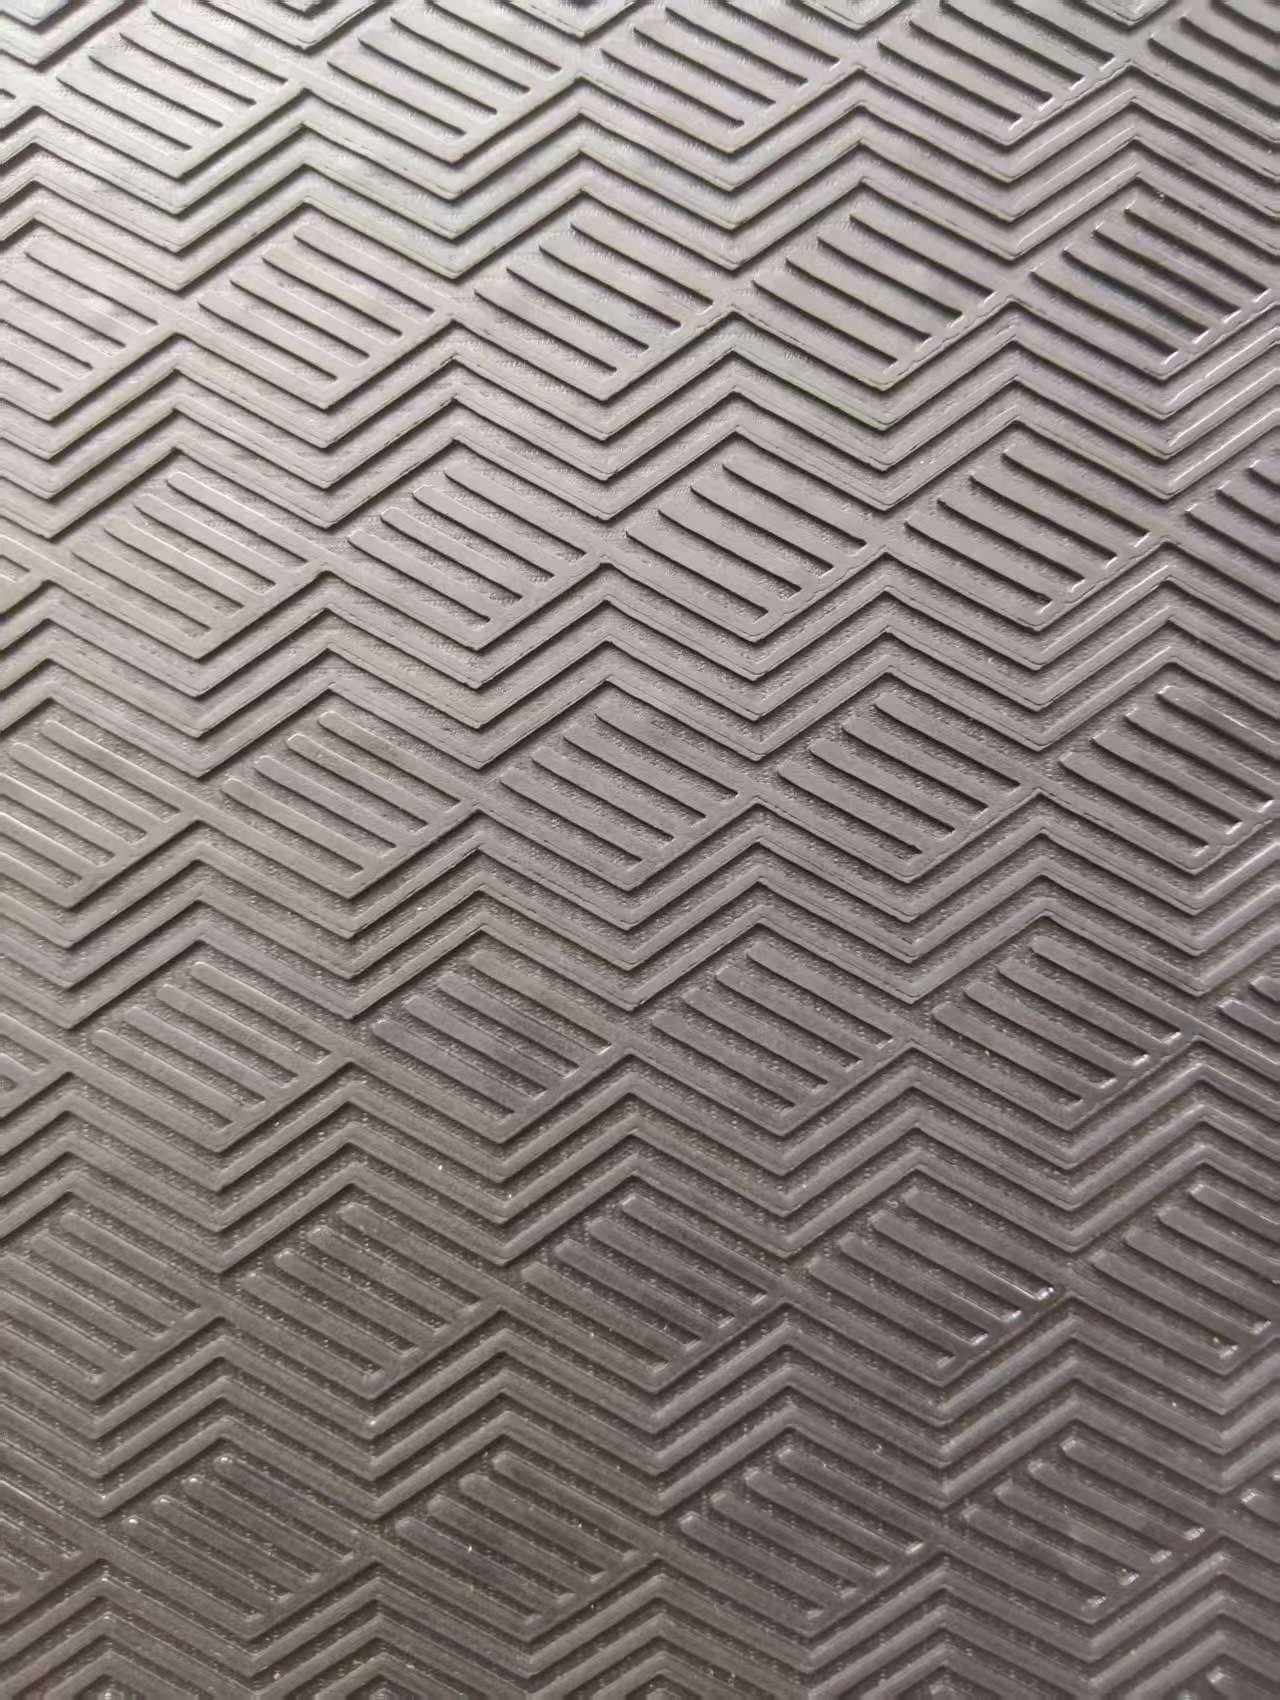
Zoned anti-slip tread inspired by the human foot
Front/Rear/Side Bumper Rubber
Bumper pads added on the toe, heel and sides absorb collision impact, protect the robot body and edges, and extend service life.
Modular Aluminum Base Plate
The standard aluminum foot plate serves as a quick-swap base decoupled from the sole and upper — only the consumable layer is replaced when worn, cutting repair cost and improving changeover efficiency.
Built-In Large-Diameter Metal Washer
When mounting the robot shoe, the lock nut clamps onto the built-in metal washer rather than the soft rubber, greatly increasing pull-out strength and preventing small-side washers from slipping or sinking into the soft sole.
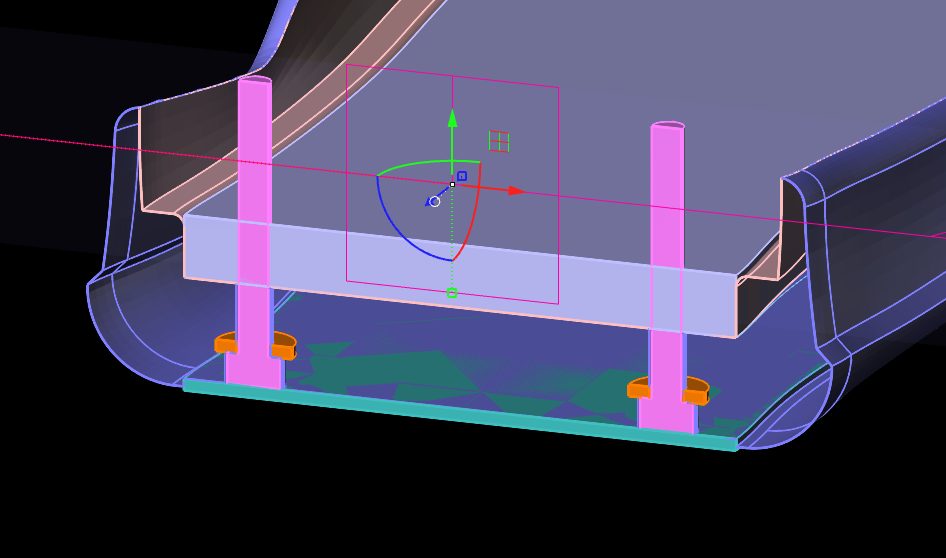
Built-in large-diameter metal washer
| Original Pain Point | RobotSole Solution |
|---|---|
| Weak shock absorption & noise | Dual-density composite (70 A wear layer + 40 A cushion layer) + high-rebound TPV, impact absorption up to standard |
| Poor terrain mobility | 10–15° / 8–12° toe-heel springs + bionic streamlined profile + zoned anti-slip tread |
| Loosening & detachment | Built-in large-diameter metal washer; nut locks on metal, pull-out strength compliant |
| Consumable, hard to maintain | Modular aluminum plate + quick-swap sole/upper; replace only the consumable layer every 1,000–2,000 h |
| No cover, no protection | Full bionic upper wrap — waterproof, dustproof, impact-proof — with space reserved for electronics |
| Too many SKUs, high cost | Standardized interface + universal foot plate, cross-generation/model interchange, fewer SKUs |
Key Technical Specifications & Three-Layer Structure
Quantified Specifications (International Baseline vs RobotSole)
| Function | Indicator | International Baseline | RobotSole Target/Measured |
|---|---|---|---|
| Damping | Shock absorption rate | ≥50% | ≥60% |
| Compression set (70°C × 24 h) | ≤20% | ≤18% | |
| Dry friction coefficient μ | ≥0.5 | ≥0.6 | |
| Anti-slip | Anti-slip angle | ≥30° | ≥35° |
| Akron abrasion | ≤0.25 cm³/1.61 km | ≤0.2 cm³/1.61 km | |
| Wear | Tensile strength | ≥13 MPa | ≥15 MPa |
| Tear strength | ≥35 kN/m | ≥40 kN/m | |
| Operating temperature range | −20 to +100°C | −30 to +300°C | |
| Physical | Hardness range (Shore A) | 60–75 A | 63–78 A |
Industry consensus: softer is not better for damping — an overly soft material compresses flat at the moment of impact and passes energy straight to the joints. Top damping materials raise stiffness progressively as they deform and keep absorbing energy. RobotSole resolves the “support vs cushion” conflict with gradient stiffness: a hard contact layer, a soft cushion layer and a rigid base layer.
Three-Layer Composite Functional Structure
A layered structure borrowing the “rigid–flexible coupling” logic of the human foot and radial tires:
| Layer | Material / Hardness |
|---|---|
Contact layer (outsole) ~70 A wear-resistant rubber | High friction, wear and oil resistance; direct ground contact and zoned anti-slip |
Cushion layer (midsole) ~40 A elastic TPV rubber, gradient foam | High-rebound energy absorption for impact dissipation and energy return |
Base layer (support) 7075 aluminum plate + large metal washer | Rigid support, standard interface, quick-swap docking |
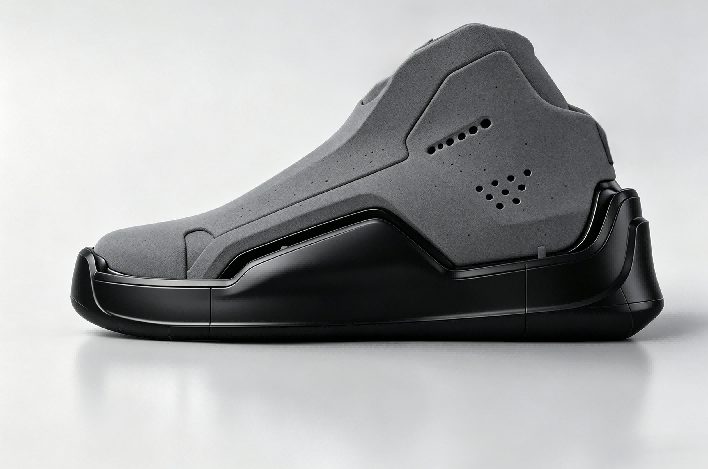
Rigid–flexible coupled three-layer structure
Dual-density shock-absorbing, quiet, wear-resistant and anti-slip outsole; full front/rear/side bumper wrap; toe-heel springs for all-terrain mobility; waterproof & dustproof PU thermoformed upper; built-in screw washers; bionic streamlined styling; easy-install shoe collar with front/rear openings; customizable logo; standardized 7075 aluminum plate.
Cost Breakdown & Delivery Cycle
Per-Unit Cost Composition (BOM Reference)
| Item | Unit Price | Note |
|---|---|---|
| Dual-density sole mold | CNY 8,300 / pair / set | One-time, per sole spec |
| PU upper thermoform mold | CNY 9,600 / pair / set | One-time, per upper spec |
| 7075 aluminum standard foot plate | CNY 125 / unit | Reusable across models |
| Robot shoe last | CNY 15 / unit | For upper forming |
| Dual-density composite sole (built-in washer) | CNY 68 / unit | Consumable layer |
| Bionic PU upper (custom logo, painting) | CNY 75 / unit | Consumable layer |
| Packaging & accessories | CNY 5 / unit | — |
Based on a 1,000-pair volume with mold costs amortized, the estimated all-in cost including the aluminum plate is about CNY 300 per shoe.
Delivery Process & Timeline
The customer pays the deposit and provides the base-plate design (hole positions, locking structure and screw specs).
RobotSole delivers 3D design drawings and renders; the robot manufacturer requests revisions.
Mold fabrication starts after final drawing sign-off, taking about 15 working days.
1–2 confirmation samples are provided after molding for verification by the robot manufacturer.
Mass production begins after confirmation — cycle depends on order volume; within 1,000 pairs it takes about 7 working days.
Recommendations & Product Roadmap
For robot makers with fast development iterations, numerous models and diverse future use environments, we propose a three-phase evolution:
Manufacture the original aluminum plate and the foot end as one integrated part with a standardized interface — eliminating delamination, detachment and damping/quietness/wear issues at the root, reducing spare-part variety for new models; different shoe types can be swapped freely under the same robot body.
Upgrade the metal foot plate to a high-strength, lighter structure fully fused with the damping layer and carbon-fiber support plate, leveraging the excellent rebound of TPV for long-term, consistent elastic damping and quietness without deformation.
In step with next-gen foot-end R&D, the future foot can integrate sensors, wireless charging and hinged two-segment plates, with thermal management, waterproofing, internal routing and customization — evolving into a “sensing foot”.
Ready to Give Your Humanoid Robot a Pair of Bionic Shoes?
Send us your base-plate drawings and robot specifications — we will return 3D designs, renders and a complete proposal within days.
Contact Us for a Proposal